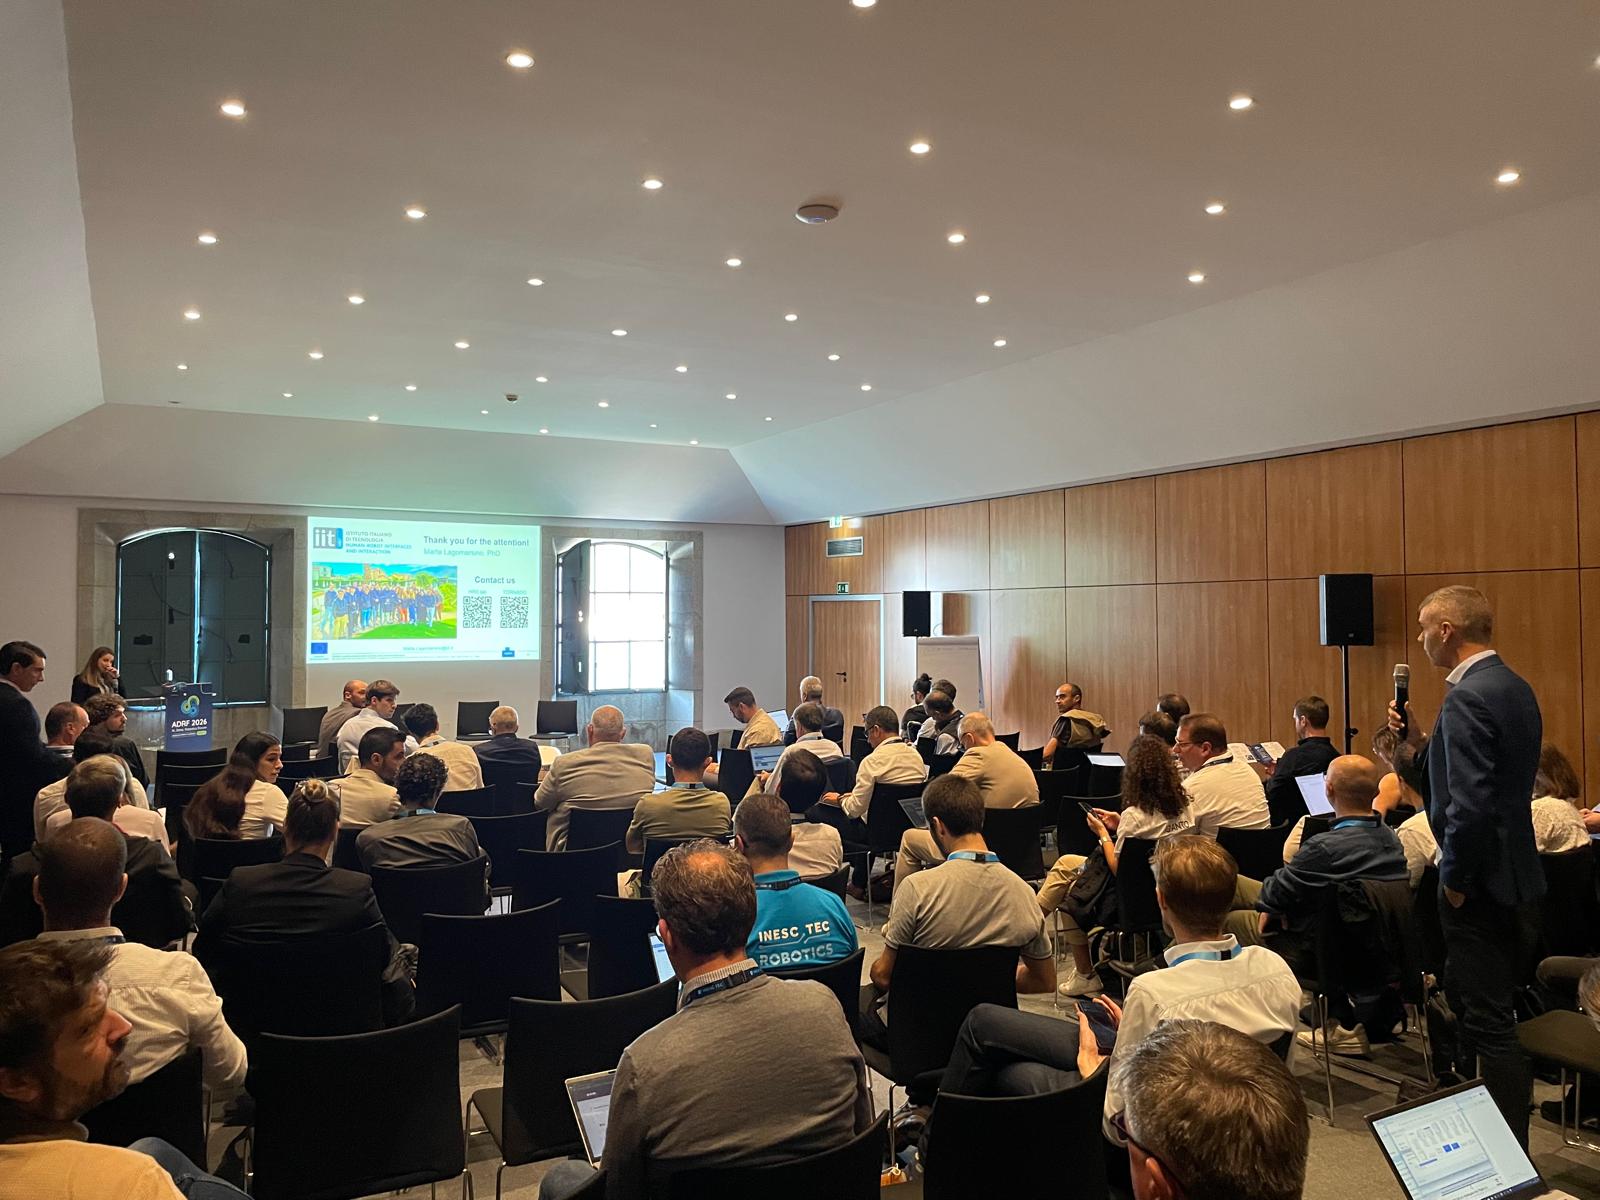
A full room in Porto: what TORNADO learned at ADRF26 | 14 October 2026
What do you need beyond good hands to put a robot to work in a hospital ward? And what do companies really want to know

What do you need beyond good hands to put a robot to work in a hospital ward? And what do companies really want to know
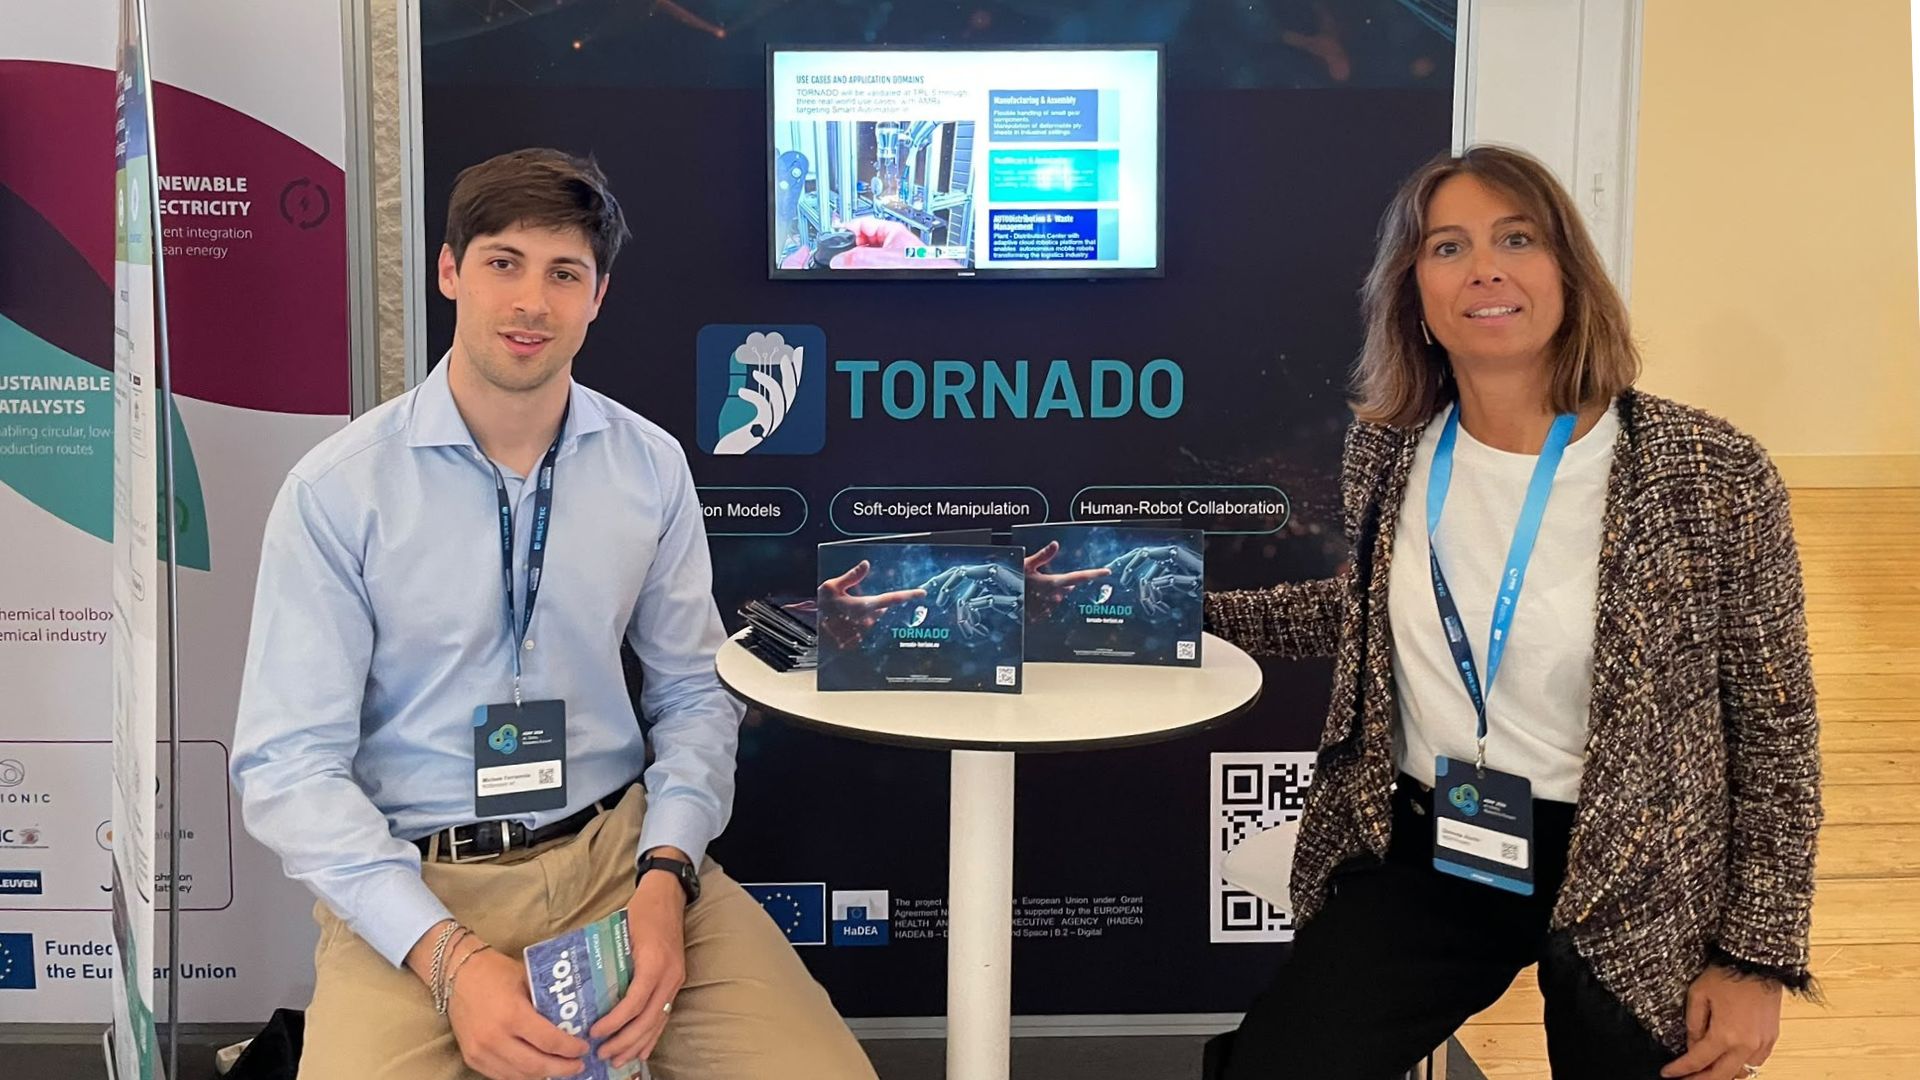
Wednesday 14 October, TORNADO opens its interactive workshop at the AI, Data and Robotics Forum. It asks how a robot that keeps learning can still
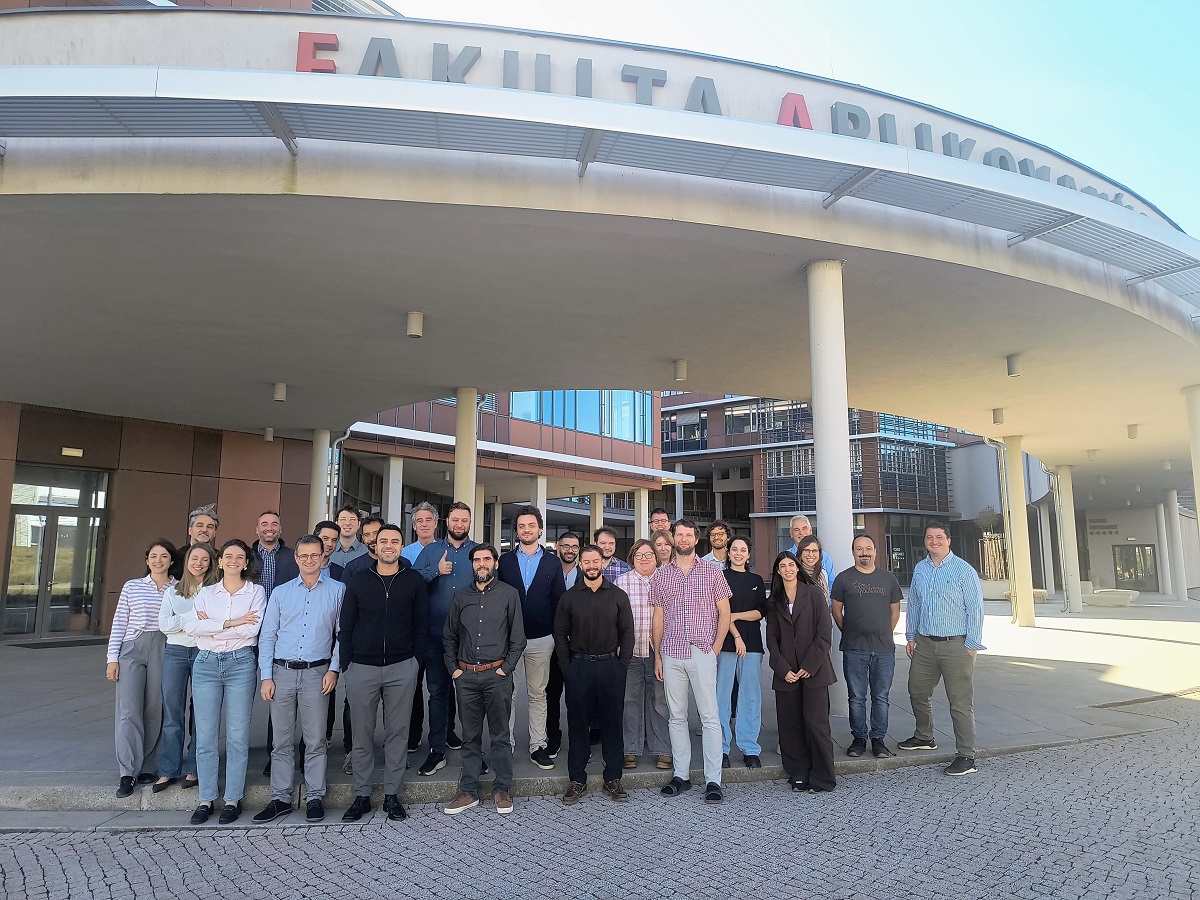
At TORNADO’s 3rd Plenary Meeting, the first robot prototypes met the software meant to make them smart, and the consortium set them a deceptively simple
A rope. A bedsheet. A suitcase on a conveyor belt. A mooring line. A wind turbine blade. A head of lettuce. Human tissue… None of
TORNADO has launched the Almanac, a dedicated digital hub tracking the latest breakthroughs in AI-powered robotic manipulation, now live at almanac.tornado-horizon.eu. Built as the project’s

The TORNADO project consortium gathered for its Second Plenary Meeting (PM2) at the Universitat Politècnica de Catalunya (UPC) in Barcelona, Spain. The two-day event brought

We are proud to share that IRCCS San Raffaele Roma took part in the Swiss Biotech Day 2026 in Basel, one of the leading global

We are pleased to share our latest work, “Foundation Models in Robotics: A Comprehensive Review of Methods, Models, Datasets, Challenges and Future Research Directions,” authored

Brussels, 16 April 2026 The TORNADO project was represented today at Future Ready 2026, the annual flagship event organised by ADRA, the AI, Data and Robotics

We are pleased to share that Aggelos Psiris, PhD Candidate and Research Associate at Harokopio University of Athens, represented the TORNADO project at the Multimodal

The first plenary meeting and general assembly of the TORNADO project took place at IRCCS San Raffaele in Rome in September 17-18, 2025. Over two

PRESS RELEASE The first Plenary Meeting and General Assembly of the European project TORNADO (foundation models for robots that handle small, soft and deformable objects)

A Human-in-the-loop Approach to Robot Action Replanning through LLM Common-Sense Reasoning Elena Merlo, Marta Lagomarsino, and Arash Ajoudani. This work was supported by the European

M. Linardakis, I. Varlamis and G. Th. Papadopoulos, “Survey on Hand Gesture Recognition From Visual Input”, IEEE Access, 2025. Hand gesture recognition has become an

Special Session: “Recent advancements in robotic perception, learning, interaction, communication, and control technologies” – Aimed to boost the potential for collaborations and clustering with existing

On May 5th, 2025, Dr. Georgios Th. Papadopoulos was invited to give a talk at the Department of Electrical and Computer Engineering of Santa Clara

On April 8th and 10th, TORNADO’s HUA team proudly took part in the Epilego Charokopio 2025 public event, organized by the Career Office of Harokopio

Guess what? The TORNADO project is making waves again with another scientific publication! Our brilliant partners at Istituto Italiano di Tecnologia (IIT) have been contributing

We’ve got an exciting news! A paper about TORNADO has just been submitted to the EEITE 2025 conference! In this paper, titled “TORNADO: Foundation Models

Published on IEEE Transactions on Robotics. We are excited to announce the first scientific publication from the TORNADO project, a key milestone since the project’s