At TORNADO’s 3rd Plenary Meeting, the first robot prototypes met the software meant to make them smart, and the consortium set them a deceptively simple challenge
Pilsen, Czechia – 29 September to 1 October 2026
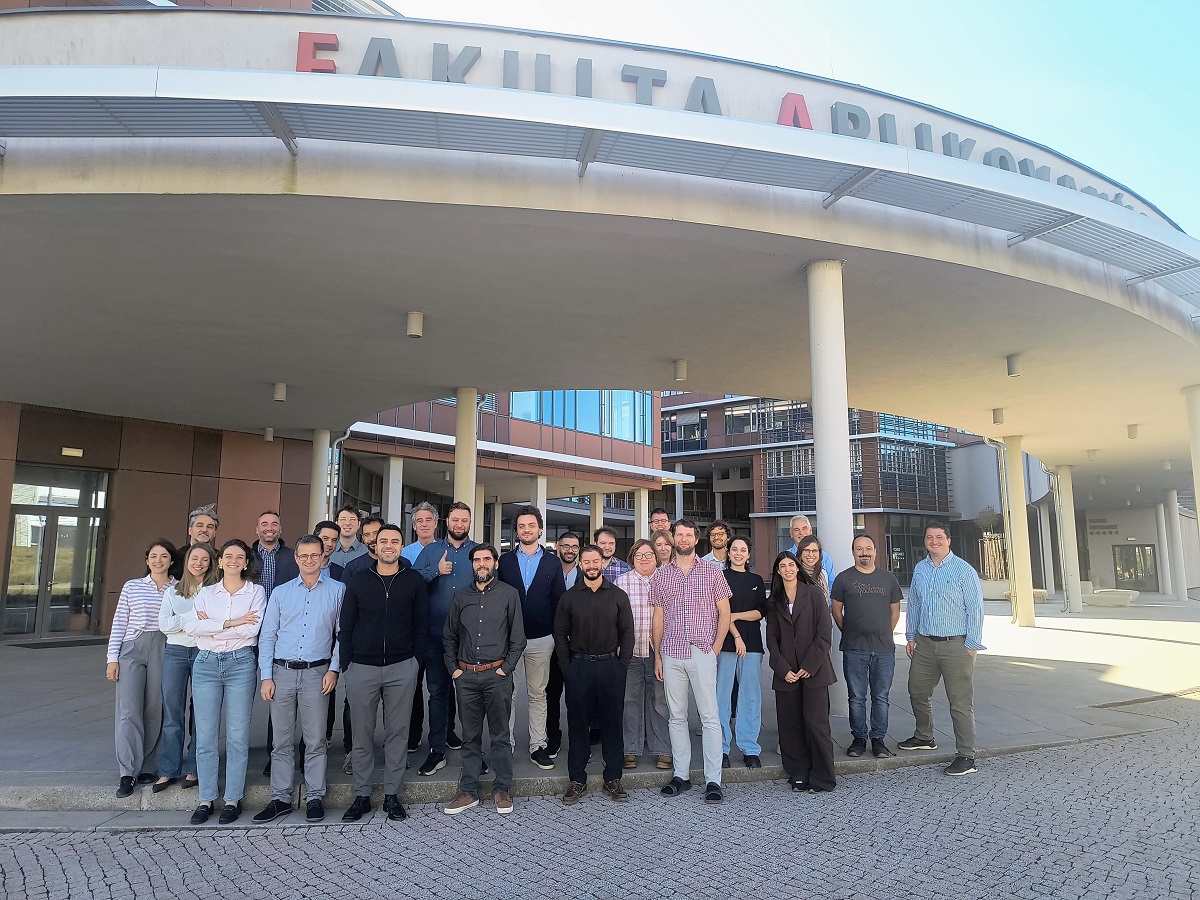
Picking up an apple sounds like the easiest task in the world. For a robot, it means finding its way down a hallway, spotting the apple among everything else around it, understanding what it has been asked to do and closing its gripper with just the right force. That small apple was waiting at the end of TORNADO‘s 3rd Plenary Meeting, hosted by the University of West Bohemia (UWB) in Pilsen.
The meeting came at a turning point for the project. The second phase is closing, the third is about to begin, and the first versions of TORNADO’s technologies are leaving the drawing board to meet real robots.
“I’m really happy to have been in Pilsen for the TORNADO 3rd Plenary Meeting, warmly hosted by UWB! It was great to have everyone together again! Over these three days, we shared ideas, celebrated progress, and looked ahead to the exciting robotics results and their impact. The Integration Workshop on the third day, focusing on the ‘Distribution & Waste Management’ pilot, was an important stepping stone towards integrating our technologies and bringing the different software pieces together. From the ITML Project Coordination side, it was great to see how all these efforts are coming together! And now, our next big milestone is just around the corner: bringing to life the first complete TORNADO robotic system prototype!”
— Nikos Nikolaou, PhD, TORNADO Project Coordinator (ITML)
Day 1: taking stock
The first day was about where TORNADO stands and where it is heading. Partners reviewed progress against the project objectives and set priorities for the months ahead.
The requirements of the three pilots came next: a precision gear factory, a palliative care ward and a distribution centre. Then the first technical results were presented:
- modules that let robots plan, navigate and manipulate objects safely;
- adaptive AI pipelines that adjust themselves when the unexpected happens, as it always does in real workplaces.
Day 2: meet the three robots
The second day opened with robotic perception and human-robot interaction: how a robot sees the world and how it understands the people working beside it. A session on system design then traced the path from architecture to integration.
After that, each of TORNADO’s three robotic systems had its own moment in the spotlight:
- Robotic system 1 pairs manipulation with perception;
- Robotic system 2 pairs navigation with perception;
- Robotic system 3 brings all three skills together.
For each robot, the teams presented the first version of the autonomous mobile platform and showed how the software modules are being tested in the lab. They also checked how ready robot and software are to work as one.
The day closed with a look at how TORNADO shares its results with the research community, industry and the public, and at the next appointment: the project’s annual event at the AI, Data and Robotics Forum in Porto.
Day 3: the apple challenge
On the final day, the teams moved to UWB’s lab and gathered around robotic system 3, the robot for the “Distribution & Waste Management” pilot. The mission was set: approach the robot, ask it to pick up an apple from the floor of a hallway, and let it do the rest.
Behind that single request, four pieces of TORNADO had to work together for the first time:
- UPC’s navigation guides the robot down the hallway;
- HUA’s perception spots the apple;
- IIT’s manipulation grasps it without bruising it;
- ITML’s small language model turns a spoken instruction into a sequence of robot actions.
For a full day, researchers from different labs and countries worked side by side, connecting, testing and adjusting until their pieces began to speak the same language. And then it happened: the robot reached the hallway, spotted the apple, understood the request and picked it up.
What’s next
The apple was only the beginning. The next milestone is the first complete TORNADO robotic system prototype, and the first public appointment is close: TORNADO will hold its annual event at ADRF26 in Porto on 13–14 October 2026.
Want to see the robot in action? Photos and videos of the apple challenge are coming in our next updates. Follow us so you don’t miss them!