A rope. A bedsheet. A suitcase on a conveyor belt. A mooring line. A wind turbine blade. A head of lettuce. Human tissue… None of those objects holds its shape, and that turned out to be the common ground of our first Technical Exchange Session with six sister projects.
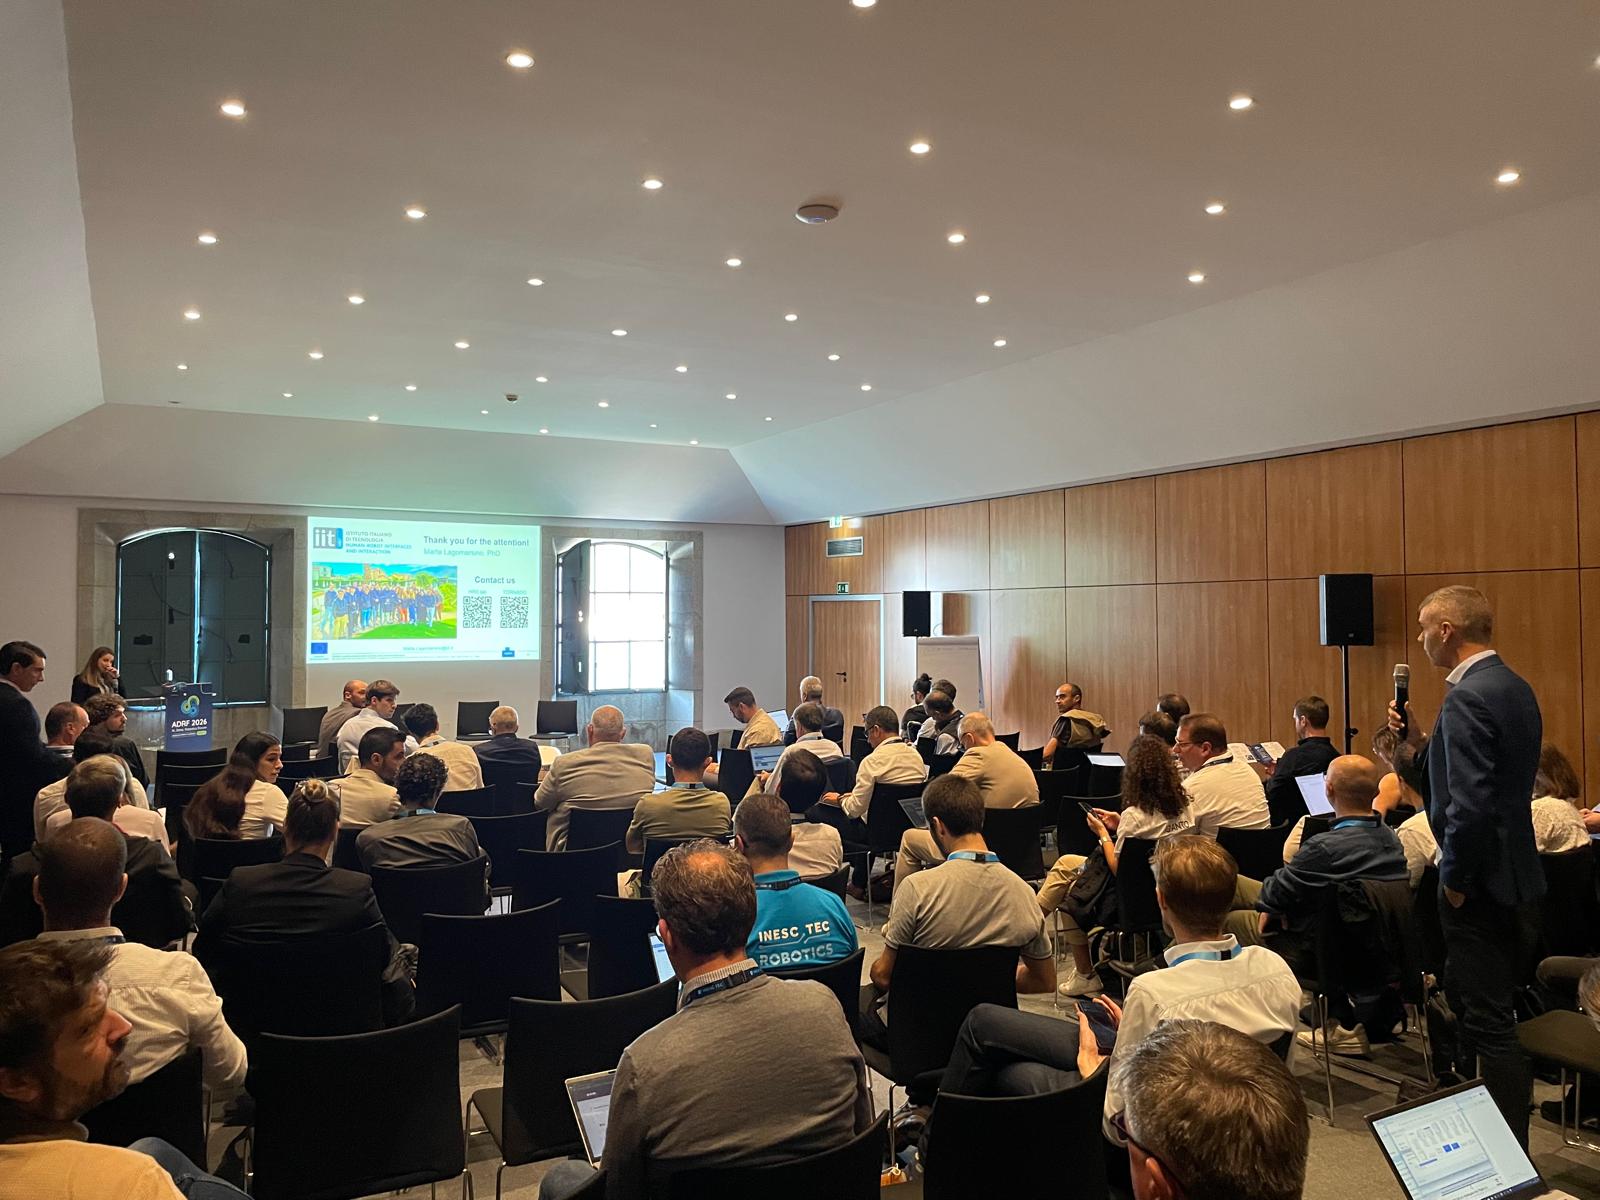
On 17 September TORNADO sat down with PRIMI, MANiBOT, AeroSub, ROB4GREEN, ARISE and SWAG. Eight minutes per project, then questions.
The questions are where it became useful. Could event cameras detect a human skeleton, and could the code behind it be shared? Was that non-prehensile manipulation strategy driven by force sensing or by contact sensing? Had anyone looked at two operators carrying the same object together? Each of those found an answer in the room, and most found someone willing to take it further.
Foundation models came up in every single presentation, applied in ways that barely overlap: turning a spoken command into a robot mission, reading a person’s intention in the middle of a shared task, segmenting a human demonstration into reusable skills. The fact that they barely overlap is exactly why there is something to learn from each other.
We are now going through the material to identify where collaboration would genuinely accelerate what we are building, and where someone in that room is further ahead than us and glad to share. Project resources are finite, so this is a question of focus: a few collaborations done properly are worth more than many done in passing.
Concrete proposals to follow.