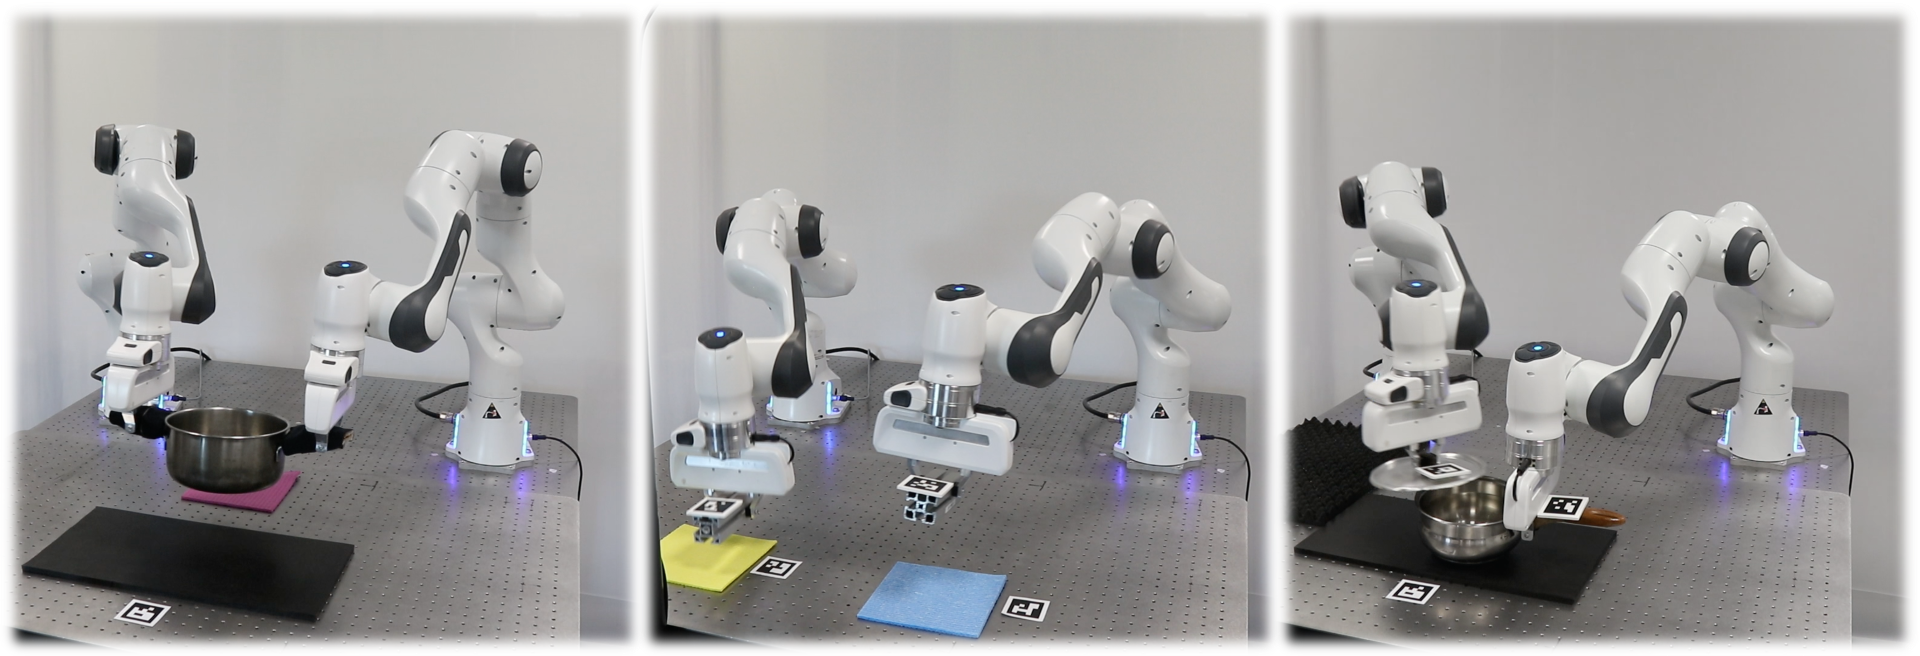
Guess what? The TORNADO project is making waves again with another scientific publication!
Our brilliant partners at Istituto Italiano di Tecnologia (IIT) have been contributing to intuitive robot programming, and their latest research about non-expert programming of bimanual activities is now available on IEEE Xplore!
What’s inside this research?
– Uses Shannon’s InformationTheory to analyze coordination between hands in bimanual tasks
– Leverages SceneGraph properties to detect interaction policies
– Outputs a modular BehaviorTree for flexible, centralized robot execution
– Validated with open-source human demonstration datasets
Why Does It Matter?
This research aligns with TORNADO’s vision helping humans to teach robots complex skills, simply:
– Empowering robots with two hands
Enables robots to learn complex bimanual tasks by watching a single video.
– One-shot learning from human demos
Transforms just one RGB video into a full plan for a two-arm robot.
– Smarter coordination, inspired by humans
Uses information theory to understand how our hands work together, letting robots mimic human-like coordination.
– Modular and adaptable behavior plans
Creates flexible, easy-to-update behavior trees that adapt to different coordination needs.
Read More & Watch the Video
📄 Full Paper on IEEE Xplore: Read here
📽️ Video Presentation: https://www.youtube.com/watch?v=RZngyFtoOoE